
Typical requirements
| Depth rating | 850 m one-atmosphere housings; to 6,000 m and full ocean depth when oil-filled |
|---|---|
| Hydrostatic pressure (rule of thumb) | About 1 bar per 10 m of seawater (600 bar at 6,000 m) |
| Thruster bus voltage | 12–20 VDC (small vehicles) to 48–330 VDC (larger electric vehicles) |
| Thruster input power | About 0.4 kW to 1 kW per thruster on small and mid-size electric vehicles |
| Winch slip ring rating | 1 kV to 7.2 kV AC; 7–125 A per pass; 5–100 rpm |
| FORJ channels | 1 (standalone FORJ) to 52 fibre passes (large hybrid winch units) |
| Housing materials | Hard-anodised 6061-T6 aluminium, 316 stainless steel, 6Al4V titanium, engineering polymers |
Machinery we specify motion for
- ROV thrusters
- AUV propulsion
- Underwater manipulators and grippers
- Camera, light and sensor pan/tilt
- Tether management systems
- Subsea cable and structure inspection vehicles
- Seabed survey systems
- Launch and recovery winches
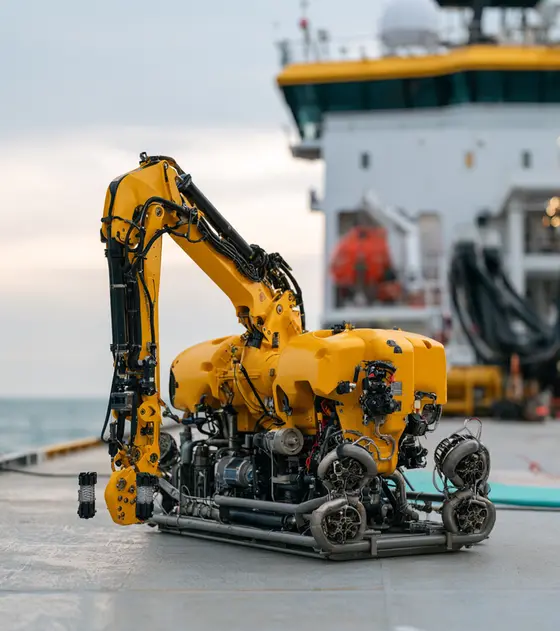
Subsea vehicles range from small tethered inspection drones to work-class ROVs and survey AUVs, but they share one design problem: water pressure rises by roughly 1 bar for every 10 m of depth, and it never lets up. Every motor, actuator, encoder and slip ring on the vehicle either has to keep the sea out at that pressure or let a compatible fluid in so that pressure stops mattering. The rest of the specification follows from that choice.
One-atmosphere housing vs pressure-compensated: the first decision
There are three ways to put a motor underwater.
| Approach | How it works | Strengths | Limits |
|---|---|---|---|
| Wet (flooded) motor | Stator potted in epoxy, rotor runs in seawater, water-lubricated bearings | Simple, light, cheap; no seals to fail | Shallow and small vehicles; corrosion and fouling on the rotor |
| One-atmosphere housing | Motor and electronics sealed in a dry pressure vessel, dynamic shaft seal or magnetic coupling | Standard industrial parts inside; electronics stay local | Housing mass rises with depth; seal is the failure point |
| Oil-filled, pressure-compensated | Cavity filled with dielectric oil, compensator keeps oil slightly above ambient | Same unit works from surface to full ocean depth | Oil drag losses, oil maintenance, electronics potted or remote |
Real products show the split. The Blue Robotics T200, common on small ROVs, has a fully potted stator and water-lubricated bearings, runs on 7–20 V and gives 5.25 kgf forward thrust at 16 V for about 390 W. Tecnadyne’s Model 580 uses a one-atmosphere housing rated to 850 m as standard (1,000 m and 1,500 m options), with a magnetic propeller coupling so no shaft seal sees the full pressure. For full ocean depth the same thruster is oil-filled and pressure-balanced, and its electronics move to a remote bottle. maxon’s oil-filled BLDC drives and thrusters are rated pressure-tolerant to 6,000 m, with one fitting for oil filling and one for the compensator.
Rule of thumb: below a few hundred metres, or when you need many actuators, compensation usually wins on mass. A one-atmosphere housing that is thin enough to be light at 100 m becomes heavy at 3,000 m.
How to specify thrusters and propulsion motors
Thrusters are outrunner or inrunner brushless DC motors, normally sensorless on small vehicles and with Hall or encoder feedback where low-speed thrust control matters (dynamic positioning, station-keeping in current). Give a supplier:
- Bollard thrust forward and reverse. Reverse is usually much lower: the T200 gives 4.1 kgf reverse against 5.25 kgf forward at 16 V, and the Tecnadyne 580 gives 10 kgf reverse against 17 kgf forward.
- Bus voltage at the vehicle, not at the surface. Long tethers drop voltage, which is why larger vehicles send power down at high voltage and convert locally. Tecnadyne offers nominal windings from 48 V to 330 VDC.
- Duty profile: transit at full thrust, hover at low thrust, and how long each lasts. Oil-filled motors lose some efficiency to oil shear at speed, and that loss is heat you have to remove.
- Mass in air and in water. Buoyancy budget is as tight as power budget on an AUV.
Size motors with our servo and stepper motor hub and compare drive options on servo drives. Low-voltage drives that accept 24–90 VDC suit most battery-powered AUVs.
Slip rings and FORJs for tethers, winches and rotating sensors
Every tethered system has at least one rotating interface at the surface: the launch and recovery winch or tether management system drum. The drum turns slowly, but it must pass high-voltage power plus data while it does.
Moog’s published winch slip ring range gives a sense of scale: models from 7 A per pass at 1 kV (the compact Model 180, 72.4 mm diameter, 100 rpm) up to 125 A per pass at 7.2 kV AC (Model 129, 50 rpm). Hybrid versions add a fibre optic rotary joint; the Model 180 can carry up to 12 singlemode and 12 multimode fibres. For single-fibre tethers, a standalone FORJ such as the FO197 is often enough. See the wider winch slip ring range.
On the vehicle itself, slip rings appear in continuously rotating sonar heads, pan-and-tilt camera units and rotating tool skids. These are normally oil-filled and compensated with the rest of the vehicle’s oil system. Moog’s downhole slip rings show that oil-filled designs can handle extreme pressure; its product guide rates the 303 series to 1,700 bar and 230 °C.
What to state: voltage per pass, current per pass and total, circuit count split between power and signal, data type (Ethernet, RS-485, coax video), fibre count and type, speed, oil or air environment, and connector standard. Read how to specify a slip ring, the marine slip ring and FORJ pages, and the subsea application page.
Actuators for manipulators, tooling and control surfaces
Work-class ROV manipulators have traditionally been hydraulic, because hydraulics give high force density and the fluid is already pressure-balanced. Electric manipulators and tooling are growing on electric vehicles, where removing the hydraulic power unit saves mass and leak risk. Typical electric subsea actuators combine a BLDC motor, planetary gearhead or screw, and an output encoder in one compensated housing; maxon describes using its screw drives in this way for grippers, manipulators and fin actuation.
For AUV fins and buoyancy-engine pistons, the key figures are holding torque or force with power off, backdrivability (do you want the fin to hold under hydrodynamic load?), and stroke. Ball screws and roller screws both work in oil; see ball screw vs roller screw and how to size a linear actuator. If you are replacing hydraulic tooling, our hydraulic to electric actuator guide covers the force and duty questions.
Encoders and feedback underwater
Optical encoders dislike oil films and contamination. Inside compensated actuators, non-contact magnetic, inductive and capacitive encoders are the safer choice. Inductive absolute encoders such as the Novanta (Celera Motion) Mini Ultra IncOder and capacitive types such as the Netzer VLP have no optical path to foul. Check that the electronics are rated for the oil, that any potting compound is compatible with it, and that the interface (SSI, BiSS-C) survives the cable run to the electronics bottle. More on choosing between technologies in absolute vs incremental encoders and the encoders hub.
Environment and compliance
- IP ratings do not equal depth ratings. IEC 60529 leaves IPX8 conditions to manufacturer–user agreement, so treat IP68 as a minimum for splash zones and deck equipment, not as a depth rating. Ask for the rated depth and the test pressure.
- Materials. Tecnadyne’s datasheet lists hard-anodised 6061-T6 aluminium, 316 stainless and 6Al4V titanium housings. Keep dissimilar metals isolated and fasteners compatible.
- Subsea production interfaces. If the vehicle operates tools on subsea production equipment, API RP 17H covers the interface design.
- Deck equipment. Launch and recovery winches are machinery; IEC 60204-1 applies to their electrical equipment.
Common pitfalls
- Specifying depth without a test margin. Agree the proof test pressure, not only the operating depth.
- Forgetting the compensator volume. Oil contracts with cold and pressure. The compensator must cover that change plus any slow leak over the service interval.
- Mixing oil-filled and dry parts on one oil circuit without checking that the oil suits every elastomer, adhesive and cable jacket in contact.
- Under-rating the tether voltage drop. Thrust collapses if the drive sees much less voltage than the motor was wound for.
- Treating the surface winch as an afterthought. The slip ring and FORJ on the drum are single points of failure for the whole system.
If you share your depth, voltage, thrust and tether details, our specialist engineering and supply partners can propose a matched set of motors, actuators, slip rings and feedback.
Subsea slip rings and FORJs for tether winches
Every tethered system has a rotating interface at the launch and recovery winch or tether management drum, and it is a single point of failure for the vehicle. The ring passes high-voltage power down the umbilical while the drum turns, and a fibre optic rotary joint carries video, sonar and control data when the tether has fibre. Specify voltage and current per pass, circuit split between power and signal, fibre count and type, insertion loss budget, drum speed and the deck environment, including washdown and salt. On the vehicle, rotating sonar heads and pan-and-tilt units use small rings, usually oil-filled on the vehicle compensation circuit.
- Launch and recovery winches: high-voltage power and fibre to the umbilical
- Tether management systems: power and data on the drum
- Rotating sonar heads: oil-filled signal rings
- Deck equipment: sealed rings for spray and washdown
Available through our supply network
All slip rings →Specify slip rings for subsea rovs and auvs →
Frameless motors for thrusters and pressure-compensated actuators
Thruster and actuator makers often build a frameless rotor and stator into their own housing, either a one-atmosphere can or an oil-filled, pressure-compensated body. That lets the motor fit the propeller hub or actuator shape and keeps the mass down. If the motor will run in oil, ask the supplier to confirm that the winding insulation, impregnation varnish, magnet bonding and lead sleeving are compatible with the chosen oil and pressure, and allow for viscous drag losses between rotor and stator at speed. Specify winding voltage for the bus at the vehicle, not at the surface, after tether voltage drop. Hall sensors or an encoder help low-speed thrust control.
- ROV and AUV thrusters: motors built into the thruster body
- Pressure-compensated manipulator joints: compact torque
- Pan-and-tilt units: direct-drive axes in oil
- AUV fin actuators: motors inside compensated housings
Available through our supply network
All frameless and torque motors →Specify frameless and torque motors for subsea rovs and auvs →
Encoders for subsea manipulators and pan/tilt units
Inside oil-filled actuators, non-contact inductive and capacitive encoders are safer than optical ones because there is no optical path for oil films or debris to foul. Confirm that the electronics and any potting are rated for the oil and the pressure, and that the interface survives the cable run to the electronics bottle; SSI and BiSS-C are common. Specify resolution, accuracy, bore and supply voltage, and ask how the encoder behaves if the oil carries wear particles. In one-atmosphere housings, standard encoders can be used, but check condensation and shock. Absolute feedback avoids homing a manipulator underwater, where a limit switch failure is expensive.
- Electric manipulators: absolute joint position
- Pan-and-tilt camera units: axis feedback in oil
- AUV fins: output angle sensing
- Tooling skids: position of rotating and linear tools
Available through our supply network
All encoders and feedback →Specify encoders and feedback for subsea rovs and auvs →
Servo drives for ROV and AUV thrusters
Thruster and actuator drives usually sit in a one-atmosphere electronics bottle, so heat has to leave by conduction through the housing wall. Rate the drive on continuous current at the bottle temperature, not in free air. Low-voltage drives that accept 24 to 90 VDC suit most battery-powered AUVs; larger electric vehicles send higher voltage down the tether and need drives that cover that bus. Specify thrust control mode (speed, torque or open loop), feedback (sensorless, Hall or encoder), network interface, and how the drive limits current when a thruster is fouled. Long motor cables to the thruster add reflected voltage and emissions, so plan filtering.
- ROV thrusters: speed and torque control from the electronics bottle
- AUV propulsion: efficient low-voltage drives
- Electric manipulators: multi-axis joint drives
- Launch and recovery winches: deck-mounted drives
Available through our supply network
All servo drives →Specify servo drives for subsea rovs and auvs →
Linear actuators for subsea tooling and launch and recovery
In-water linear actuators are usually purpose-built: a brushless motor, gearhead or screw and encoder in one oil-filled, pressure-compensated housing. Ball and roller screws both run in oil, and the choice follows force, life and shock load. On deck, launch and recovery systems, latches, docking heads and hatches can use sealed industrial actuators, and electric roller-screw units can replace hydraulic cylinders where removing the power pack saves weight and leak risk. Specify force, stroke, speed, duty, holding behaviour with power off, and environment. For deck units, check the IP rating, materials and temperature range against spray, washdown and the coldest operating day.
- Launch and recovery systems: latches and docking heads
- Deck handling: hydraulic cylinder replacement
- Vessel hatches and doors: sealed electric actuation
- AUV buoyancy engines: piston drive in compensated housings
Available through our supply network
All linear actuators →Specify linear actuators for subsea rovs and auvs →
Sealed gearheads for subsea manipulators
Electric manipulator joints and pan-and-tilt units need gearing that gives high torque from a small motor and holds position. Inside a pressure-compensated housing, the gear runs in the compensating oil, so check that its lubricant, seals and any plastics are compatible, and that the gear efficiency figures still apply with oil drag. Strain-wave gearing gives zero backlash and a hollow centre for wiring; planetary gearheads give robust high-ratio reduction. Corrosion-resistant stainless versions suit splash-zone and deck equipment. Specify output torque, holding torque, backlash, shock load from tooling, and whether the joint must be backdrivable so a stuck manipulator can be recovered.
- Electric manipulators: high-ratio joint reduction
- Pan-and-tilt units: low-backlash geared axes
- Tooling skids: torque tools and rotary tools
- Deck equipment: corrosion-resistant gearheads
Available through our supply network
All gearboxes and harmonic drives →Specify gearboxes and harmonic drives for subsea rovs and auvs →
Standards to have in view
- IEC 60529 (IP codes)
- API RP 17H (remotely operated tools and interfaces on subsea production systems)
- IEC 60204-1 (electrical equipment of machines, for launch and recovery winches)
Which standards apply depends on the end product and its market. Your engineer will confirm what the component itself needs to meet.