
Gearboxes and harmonic drives
Precision reducers that match motor speed and torque to the load, from planetary to zero-backlash strain-wave gearing. Tell us the application and we'll specify the right product, and the parts around it, for your machine.
Pricing and availability
Get help selecting and sourcing gearboxes and harmonic drives
Send us a part number, or tell us what the machine needs to do. Our UK engineers will come back with the right product, pricing, lead time and delivery, whether that is the original part, a checked alternative or a complete axis.
- Original parts or a checked alternative
- Pricing, lead time and delivery in one reply
- Components, complete axes and ongoing support
No obligation. Add what you know and an engineer will help with the rest. Prefer to configure it? Build a specification.
Spec builder
Specify gearboxes and harmonic drives
Select every part you need and answer the questions an applications engineer would ask. Our engineers use your specification to come back with the right products, pricing and lead times. You see your summary before we ask for any details.
Already know the part number? Send it to us directly.
- 1Products
- 2Performance
- 3Environment
- 4Volumes
- 5Your spec
What are you specifying?
Select everything you need. A motor, drive and gearbox can be specified together as one axis.
What a precision gearbox does
A gearbox between a servo or stepper motor and its load does three jobs. It multiplies torque, so a smaller motor can drive the load. It reduces speed to what the load needs. And it divides the load inertia seen by the motor by the square of the ratio, which makes the axis easier to control.
The cost is backlash, compliance, friction losses and extra inertia. Choosing a gearbox for a motion axis is mostly about how much of each you can accept for the torque, ratio and space you have.
Gearbox types compared
| Type | Typical ratio per stage | Backlash | Efficiency | Best for |
|---|---|---|---|---|
| Planetary (inline) | 3:1 to 10:1 | Standard grades several arcmin; precision grades down to about 1 arcmin | About 97% one stage, 95% two stage | General servo axes, high stiffness per size |
| Strain-wave (harmonic) | About 30:1 to 160:1 | Zero at the mesh; lost motion under 1 arcmin | Varies widely with speed, torque and temperature | Robot joints, compact high-ratio, hollow shaft |
| Cycloidal | Up to about 185:1 | About 1 arcmin or less | Up to about 85% (RV-N) | Heavy, shock-loaded joints and positioners |
| Spiral bevel (right-angle) | Low single stage; combined with planetary up to about 200:1 | Typically 10–30 arcmin in plain bevel sets | Up to about 98% per mesh | Right-angle layouts, short envelope |
| Worm | High single stage | Varies widely | Low, falling with ratio | Low-duty right-angle drives, holding |
Figures are drawn from the Design World gearbox guide, Beckhoff AG3210 data, Harmonic Drive CSG-2A data and Nabtesco RV-N data listed in the sources. Individual series vary.
Planetary gearboxes
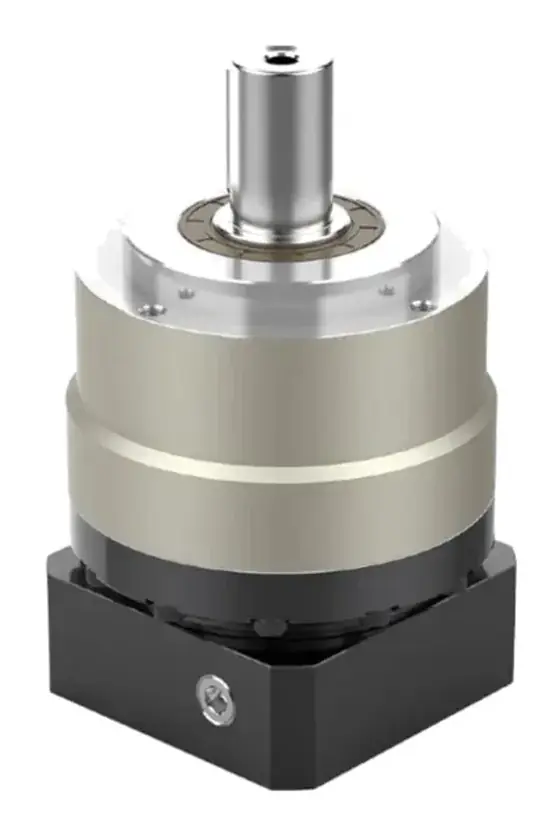
Planetary gearheads are the default for servo motors. Load is shared between several planets, giving high torque and stiffness in a short, coaxial package. Beckhoff’s AG3210 data, for example, quotes 97% efficiency for one stage and 95% for two, with standard backlash of up to 8 and 10 arcmin respectively (Beckhoff). Precision ranges go much lower: Apex AD/ADR and Wanshsin WSH offer backlash classes around 1 to 1.5 arcmin in single stage. Apex AB/ABR is a lower-backlash general-purpose range, and Harmonic Drive HPG uses a flexible internal gear to hold backlash low over life. For AGV wheels, rotating-housing designs such as Apex GL let the wheel mount directly on the gearbox.
Strain-wave (harmonic) gearing
An elliptical wave generator flexes a thin toothed cup (the flexspline) inside a rigid ring (the circular spline) that has two more teeth. Each turn of the wave generator moves the flexspline by two teeth, which is why single-stage ratios are so high. Harmonic Drive states that up to 30% of teeth are engaged at once (Harmonic Drive). Harmonic Drive is a trademark of Harmonic Drive LLC; strain-wave gearing is the generic term.
Component sets such as Harmonic Drive CSG, Harmonic Drive SHG and LeaderDrive LCS/LCSG are built into your own housing. Hollow-shaft units such as LeaderDrive LHS/LHSG pass cables through the centre. For CSG-2A, Harmonic Drive quotes lost motion and hysteresis loss under 1 arcmin, transmission accuracy under 1–1.5 arcmin depending on size, and repeatability under ±0.1 arcmin (CSG-2A data).
Cycloidal reducers
Cycloidal reducers drive lobed discs around pins. Many contact points share the load, giving high shock capacity and stiffness. Nabtesco’s RV-N range allows acceleration torque of 2.5 times rated and emergency-stop torque of five times rated, with lost motion under 1 arcmin on most sizes and efficiency up to 85% (Nabtesco). They tend to be the heaviest option for a given rated torque but cope best with collisions and heavy payloads.
Spiral bevel and right-angle planetary
Right-angle units fold the motor alongside the machine. Most precision servo versions add a spiral bevel stage to a planetary, for example Wanshsin WSHR and Apex AER/ADR. Spiral bevel meshes run at up to about 98% efficiency (Design World). For rotary tables, hollow-platform reducers such as Wanshsin WTN combine gearing with a crossed roller output bearing.
Worm gearboxes
Worms give a high ratio in one right-angle stage and can resist back-driving, but sliding contact means more heat and lower efficiency. Boston Gear’s engineering data estimates efficiency from lead angle and friction, and notes that self-locking may be expected below about 5° lead angle and back-driving above about 11°, without guarantee (Boston Gear). They are rarely the first choice on dynamic servo axes.
How to select and size a gearbox
1. Choose the ratio
Ratio = motor speed at full load speed ÷ required output speed, then check torque: output torque ≈ motor torque × ratio × efficiency. Also check the inertia ratio. Reflected load inertia = J_load / i². Most servo sizing aims for a load-to-motor inertia ratio of 10:1 or less (Motion Control Tips).
Worked example: a rotary table needs 60 rpm and 40 Nm, with 0.5 kg·m² inertia. A 3,000 rpm servo gives a ratio of 50:1. Motor torque ≈ 40 / (50 × 0.9) ≈ 0.9 Nm before acceleration. Reflected inertia = 0.5 / 2,500 = 0.0002 kg·m² (2 kg·cm²), which suits a motor with rotor inertia around 0.2 kg·cm² or more. At 50:1 you could use a two-stage planetary or a single-stage strain-wave gear; the choice comes down to backlash, stiffness and envelope.
2. Check the torque definitions
Precision gearbox catalogues usually give several torque limits rather than one rating:
- Rated (nominal) torque: the continuous reference for life. Harmonic Drive notes it is used for life calculation, not for dimensioning the gear.
- Repeatable peak / acceleration torque: the limit during normal acceleration and braking, sometimes at a stated maximum cycles per hour.
- Momentary / emergency-stop torque: for collisions or E-stops only, often limited to a set number of events over the gearbox life.
Check every torque in your cycle against the right limit. Servo motors can produce several times their rated torque, so an E-stop or a tuning error can exceed the gearbox’s peak limit. Limit drive current if necessary.
3. Check life and average torque
For strain-wave gears, life is governed by the wave generator bearing. Harmonic Drive gives L50 = Ln × (rated input speed ÷ average input speed) × (rated torque ÷ average torque)³, with Ln = 50,000 h for CSG. Planetary catalogues quote a service life at rated torque and speed. Either way, life falls steeply as average torque rises.
4. Backlash, lost motion and stiffness
Backlash matters when the load reverses. Stiffness matters for positioning under load and for servo bandwidth. Torsional wind-up = torque ÷ stiffness: a gearbox at 20 Nm/arcmin carrying 100 Nm twists 5 arcmin, which can be more than its backlash. Strain-wave stiffness is non-linear, with lower stiffness at low torque (Harmonic Drive’s K1, K2 and K3 regions), so use the region that matches your working torque.
5. Service factors, shock and duty
General-purpose gear drives use service factors for shock, start frequency and running hours. Precision servo gearboxes usually deal with this through the acceleration and emergency torque limits above. Either way, describe the load honestly: start-stops per hour, reversals, shock and hours per day.
6. Input speed, temperature and mounting
Check maximum and average input speed, as these drive heat and life. Check the motor adaptor fits your motor’s shaft and pilot, and the output bearing’s tilting moment and radial capacity against the load. An integrated output bearing often removes a separate bearing from the design.
For a deeper comparison, read harmonic vs planetary vs cycloidal.
Common mistakes
- Sizing on rated torque alone. Acceleration and E-stop peaks are often the limiting case.
- Confusing zero backlash with zero error. Stiffness and transmission accuracy still matter.
- Too high a ratio. The motor runs out of speed and the gearbox’s own inertia dominates.
- Relying on worm self-locking. Fit a brake where holding is safety-related.
- Ignoring output bearing loads. Pulleys, pinions and overhung tables load the output bearing as well as the gears.
- Not limiting motor current. A servo can exceed the gearbox’s momentary limit in a crash.
What to send an engineer for a quote
- Motor make, model, flange and shaft (or the motor you plan to use)
- Required output speed and torque profile, including acceleration and E-stop torques
- Load inertia, start-stops per hour, hours per day and expected life
- Allowable backlash, lost motion and stiffness
- Inline or right-angle, hollow shaft, and envelope limits
- Output loads: radial, axial and tilting moment
- Environment: temperature, IP rating, washdown, mounting orientation
Add these to the spec builder below and our engineers will propose a matched gearbox, or a frameless motor and gear combination where integration makes more sense.
Guides
Where gearboxes and harmonic drives are used
What we need to know to specify gearboxes and harmonic drives
These are the questions an applications engineer works through first. Approximate answers are fine: ranges narrow the options quickly, and we confirm the details with you.
- Type: Harmonic / strain wave, Planetary, Spiral bevel, Not sure
- Ratio: Under 10:1, 10–50:1, 50–100:1, Over 100:1
- Backlash: Zero / under 1 arcmin, Under 3 arcmin, Standard
- Output torque: Under 20 Nm, 20–100 Nm, 100–500 Nm, Over 500 Nm
We also ask about the environment (washdown, outdoor, subsea, ATEX, vacuum, shock and EMC), annual quantities and timescale, because these decide whether a standard, modified or custom design is the best fit.
124 series compared
Series from 30 manufacturers, grouped by type. Figures are the highest published for each series. Open a series for the full specification and, for brands outside our supply network, the alternatives that meet or exceed it.
Planetary gearbox (42)
| Brand | Series | Rated torque | Peak torque | Ratio (max) |
|---|---|---|---|---|
| APEX Dynamics | P-II / P-IIR | 459 Nm | — | 1,000:1 |
| APEX Dynamics | AD / ADR / ADS | — | — | — |
| APEX Dynamics | GL / GLS | — | — | 90:1 |
| APEX Dynamics | AB / ABR | — | — | — |
| Wanshsin | WSH | 2,400 Nm | 7,200 Nm | 100:1 |
| Wanshsin | WTH | 2,050 Nm | 6,150 Nm | 100:1 |
| Wanshsin | WAE | — | — | — |
| Wanshsin | WVRB | — | — | — |
| Wanshsin | WTN | — | — | — |
| Wanshsin | WPL / WPF | — | — | 100:1 |
| FAULHABER | GPT planetary gearheads | 18 Nm | — | 1,437:1 |
| WITTENSTEIN alpha | alpha SP+ | — | 5,700 Nm | 100:1 |
| WITTENSTEIN alpha | alpha TP+ | — | 22,000 Nm | 302.5:1 |
| WITTENSTEIN alpha | alpha XP+ | — | 3,840 Nm | 100:1 |
| WITTENSTEIN alpha | alpha RP+ | — | 10,450 Nm | 220:1 |
| WITTENSTEIN alpha | alpha NP (incl. NPR / NPS / NTP) | — | 800 Nm | 100:1 |
| WITTENSTEIN alpha | alpha CP | — | 800 Nm | 100:1 |
| WITTENSTEIN alpha | alpha LP+ / LPB+ | — | 305 Nm | 100:1 |
| maxon | GPX | 70 Nm | 87.5 Nm | 1,526:1 |
| Harmonic Drive | HPG Harmonic Planetary gearheads | 850 Nm | 4,500 Nm | 50:1 |
| Harmonic Drive | HPN Harmonic Planetary value series | 562 Nm | 1,265 Nm | 50:1 |
| Lenze | g7x0-P planetary gearboxes | — | — | — |
| STOBER | P planetary gearboxes | — | — | 100:1 |
| STOBER | PH planetary gearboxes | — | — | 100:1 |
| STOBER | PHQ planetary gearboxes | — | — | 600:1 |
| SEW-EURODRIVE | PxG planetary servo gear units (P5.G, P6.G, P7.G) | — | 6,150 Nm | 1,000:1 |
| Neugart | PLE economy planetary gearbox | 680 Nm | 1,280 Nm | 512:1 |
| Neugart | PLN precision planetary gearbox | 900 Nm | 2,880 Nm | 100:1 |
| Neugart | PSNpro helical precision planetary gearbox | 1,530 Nm | 2,210 Nm | 100:1 |
| Neugart | WPLE economy right-angle planetary gearbox | 220 Nm | 415 Nm | 512:1 |
| Neugart | PLFE economy planetary gearbox with flange output | 220 Nm | 415 Nm | 100:1 |
| Bonfiglioli | TQ in-line precision planetary gearboxes | 800 Nm | — | 100:1 |
| Bonfiglioli | TQK right-angle precision planetary gearboxes | 800 Nm | — | 100:1 |
| Bonfiglioli | TQF flange-output precision planetary gearboxes | 800 Nm | — | — |
| Bonfiglioli | LC in-line precision planetary gearboxes | 450 Nm | — | 100:1 |
| Bonfiglioli | MP precision planetary gearboxes | 1,000 Nm | — | — |
| Nidec | ABLE VRB | — | — | 100:1 |
| Nidec | ABLE VRL | — | — | 100:1 |
| Nidec | ABLE VRS | — | — | 100:1 |
| Nidec | ABLE VRT | — | — | 100:1 |
| Portescap | R22 planetary gearhead | 0.6 Nm | 2 Nm | 1,090:1 |
| Portescap | R22HT planetary gearhead | 3.7 Nm | 4.2 Nm | 850.3:1 |
Integrated robot joint actuator (30)
| Brand | Series | Peak torque | Rated torque | Speed |
|---|---|---|---|---|
| CubeMars | AK Series | 120 Nm | 48 Nm | 800 rpm |
| CubeMars | AKE Series | 170 Nm | 55 Nm | 330 rpm |
| MYACTUATOR | RMD-X V4 | 450 Nm | — | — |
| MYACTUATOR | RMD-X V2/V3 (earlier models)discontinued | — | — | — |
| Unitree | GO-M8010-6 | 23.7 Nm | — | 286 rpm |
| Unitree | B1-16 waterproof joint | 140 Nm | — | — |
| Unitree | Bionic joint motor IM6014 (N6014B) | 34.4 Nm | — | 517 rpm |
| Unitree | A1 joint motor | 33.5 Nm | — | 200 rpm |
| igus | ReBeL gearbox (robolink) | 20 Nm | 15 Nm | 10 rpm |
| RobStride | RobStride 02 (RS02) | 17 Nm | 6 Nm | 410 rpm |
| RobStride | RobStride 03 (RS03) | 60 Nm | 20 Nm | 200 rpm |
| DaMiao | DM-J4310-2EC | 18 Nm | 5.2 Nm | — |
| DaMiao | DM-J6216-2EC (P and L versions) | 45 Nm | 10 Nm | — |
| DaMiao | DM-J8009P-2EC | 40 Nm | 20 Nm | — |
| DaMiao | DM-J8520P-2EC | 176 Nm | 50 Nm | — |
| SteadyWin | GIM Series | — | — | — |
| SteadyWin | TT Series | 60.07 Nm | 13 Nm | 307.8 rpm |
| SteadyWin | WGG Series (exoskeleton motors) | 24.78 Nm | 10.2 Nm | 390 rpm |
| HEBI Robotics | T-Series | 80 Nm | 40 Nm | 118 rpm |
| HEBI Robotics | R-Series | 80 Nm | 40 Nm | 118 rpm |
| HEBI Robotics | H-Series | 280 Nm | 140 Nm | 100 rpm |
| HEBI Robotics | X-Serieslegacy | 38 Nm | 16 Nm | 90 rpm |
| Synapticon | ACTILINK-JP | 411 Nm | 137 Nm | 70 rpm |
| Laifual Drive | DC low-voltage joint modules | — | — | — |
| MAB Robotics | MA-p planetary actuators | 18 Nm | 9 Nm | 603 rpm |
| MAB Robotics | MA-D direct-drive actuators | 2.9 Nm | 1 Nm | 2,390 rpm |
| HighTorque | HTDW servo joint modules | 60 Nm | 10 Nm | — |
| HighTorque | HTPU ultra-thin joint modules | 50 Nm | 20 Nm | 60 rpm |
| HighTorque | HTCP joint modules | — | 4 Nm | — |
| HighTorque | HTPW-7507 | — | 4 Nm | — |
Strain-wave (harmonic) gear (16)
| Brand | Series | Rated torque | Peak torque | Ratio (max) |
|---|---|---|---|---|
| LeaderDrive | LCS / LCSG | — | — | 500:1 |
| LeaderDrive | LHS / LHSG | — | — | 500:1 |
| LeaderDrive | LCD | — | — | 500:1 |
| LeaderDrive | LHD | — | — | 500:1 |
| Harmonic Drive | CSF-2A component sets | 3,550 Nm | 15,500 Nm | 160:1 |
| Harmonic Drive | CSG-2A component sets | 1,236 Nm | 6,175 Nm | 160:1 |
| Harmonic Drive | CSD-2A component sets | 329 Nm | 1,440 Nm | 160:1 |
| Harmonic Drive | SHF-2A component sets | 745 Nm | 3,430 Nm | 160:1 |
| Harmonic Drive | SHG-2A component sets | 1,236 Nm | 6,175 Nm | 160:1 |
| Harmonic Drive | SHD-2SH gear units | 185 Nm | 700 Nm | 160:1 |
| Harmonic Drive | CPU-M / CPU-H / CPU-S gear units | — | 1,840 Nm | 160:1 |
| Harmonic Drive | CPL-2A component sets | — | 372 Nm | 160:1 |
| Nidec | FLEXWAVE strain wave reducers | — | — | 160:1 |
| Laifual Drive | FSS (FS standard) | 294 Nm | 647 Nm | 160:1 |
| Laifual Drive | FSG (FS high-torque) | 382 Nm | 841 Nm | 160:1 |
| Laifual Drive | FSD (FS ultra-thin) | 96 Nm | — | 100:1 |
Harmonic actuator (14)
| Brand | Series | Peak torque | Rated torque | Speed |
|---|---|---|---|---|
| Motion Control Products | MAH | 800 Nm | 557 Nm | 125 rpm |
| Motion Control Products | MAT | 800 Nm | 557 Nm | 102 rpm |
| Motion Control Products | MGM | 459 Nm | 267 Nm | 108 rpm |
| Motion Control Products | MGU | 762 Nm | 557 Nm | 68 rpm |
| Harmonic Drive | FHA-C hollow-shaft servo actuators | 820 Nm | — | 96 rpm |
| Harmonic Drive | SHA-SG hollow-shaft servo actuators | 3,419 Nm | 1,236 Nm | 509.1 rpm |
| Harmonic Drive | SHA-CG hollow-shaft servo actuators | 841 Nm | 382 Nm | 120 rpm |
| Harmonic Drive | RSF servo actuators (17A/20A/25A/32A) | 330 Nm | 98 Nm | — |
| Harmonic Drive | LPA low-profile actuator with integrated servo drive | 57 Nm | 16.9 Nm | 88.2 rpm |
| MYACTUATOR | RH Series | — | — | — |
| Spinea | DriveSpin DSH hollow-shaft actuators | — | 420 Nm | — |
| Spinea | DriveSpin DS standard actuators | — | 460 Nm | — |
| Laifual Drive | AC high-voltage joint modules | — | — | — |
| MAB Robotics | MA-H harmonic actuators | — | — | — |
Cycloidal gearbox (14)
| Brand | Series | Rated torque | Peak torque | Ratio (max) |
|---|---|---|---|---|
| Nabtesco | RV-N cycloidal gear component sets | 28,000 Nm | 70,000 Nm | 316.71:1 |
| Nabtesco | RV-C hollow-shaft cycloidal gear component sets | 11,760 Nm | 29,400 Nm | 42.84:1 |
| Nabtesco | RD-C hollow-shaft cycloidal gearboxes | 3,136 Nm | 7,840 Nm | 258:1 |
| Nabtesco | Neco and Neco HT cycloidal gearboxes | 9,000 Nm | 22,500 Nm | 313:1 |
| Sumitomo Drive Technologies | Fine Cyclo A-Series (F1, F2, F3, FC types) | — | 7,610 Nm | 179:1 |
| Sumitomo Drive Technologies | Fine Cyclo C-Series | — | 6,278 Nm | 119:1 |
| Sumitomo Drive Technologies | Fine Cyclo DA-Series | — | 4,000 Nm | 119:1 |
| Sumitomo Drive Technologies | Fine Cyclo UA-Series | — | 30,000 Nm | 283:1 |
| Sumitomo Drive Technologies | Fine Cyclo T-Series | — | 11,000 Nm | 171:1 |
| Sumitomo Drive Technologies | Fine Cyclo W-Series | — | 10,000 Nm | 87:1 |
| Spinea | TwinSpin T series | 2,940 Nm | 7,350 Nm | 191:1 |
| Spinea | TwinSpin E series | 1,250 Nm | 3,125 Nm | 169:1 |
| Spinea | TwinSpin H series (hollow shaft) | 2,750 Nm | — | 125:1 |
| Spinea | TwinSpin M series | 18 Nm | 36 Nm | 63:1 |
Spiral bevel gearbox (6)
| Brand | Series | Rated torque | Peak torque | Ratio (max) |
|---|---|---|---|---|
| Wanshsin | WSHR | 1,400 Nm | 4,200 Nm | 200:1 |
| Wanshsin | WTHR | 2,050 Nm | 6,150 Nm | 200:1 |
| Wanshsin | WAER | — | — | 200:1 |
| Wanshsin | WADR | — | — | 200:1 |
| Wanshsin | WVRBR | 2,000 Nm | — | 200:1 |
| Nidec | ABLE EVS | — | — | 100:1 |
Stainless planetary gearbox (1)
| Brand | Series | Rated torque | Peak torque | Ratio (max) |
|---|---|---|---|---|
| APEX Dynamics | AE / AER / AES / AESR | — | — | 200:1 |
Worm gearbox (1)
| Brand | Series | Rated torque | Peak torque | Ratio (max) |
|---|---|---|---|---|
| Motion Control Products | MCP2 / MCP4 worm wheel gearbox | — | — | 60:1 |
Summarised from manufacturers' published data. Always confirm against the current datasheet; an engineer will check the fit before recommending anything.
Brands
Engineer support
Talk to an engineer about gearboxes and harmonic drives
Tell us the part or application, quantity and timing. Our UK engineers will come back with the right product, pricing, lead time and delivery.
- Reviewed by an engineer, not an autoresponder
- Like-for-like and better-fit alternatives
- Standard, modified and custom options
Prefer to configure it? Use the spec builder.
From component to working requirement
Applications and engineering services
Explore selection questions, replacement routes and complete motion packages. Keep the application requirements alongside the product specifications.
Compact low-backlash gearbox selection
Small size and low backlash are useful only if torque, stiffness, life and installation requirements are also satisfied. Evaluate the complete motor-gearbox-load assembly.
Complete servo motor, drive and gearbox packages
Choose the axis from the load backwards. A matched package is a defined combination of components and interfaces, with the scope of supply agreed before purchase.
Motors and drives for AGV and AMR traction
A traction selection needs wheel torque and speed across the vehicle duty. Battery limits, regeneration, gearing, holding and steering arrangements also matter.
Servo motion for rotary indexing tables
Indexing performance depends on the complete move and settle cycle. Table diameter or payload alone cannot establish motor torque or gearbox suitability.
How it works
From enquiry to delivery
Send a part number or describe the application. Our engineers take it from there: the right product, a clear quotation, and delivery and support arranged.
- 01Tell us what you needSend a part number, or configure the application, quantities and timing.
- 02An engineer reviews itWe check the specification and find the original part, a checked equivalent or a complete axis.
- 03Receive your quotationProducts, pricing, lead time and compatibility notes in one reply.
- 04Order and deliveryWhen you are happy, the order is placed and delivery and after-sales support are arranged.