
Encoders and feedback
Position and speed feedback for closed-loop motion, rotary and linear, absolute and incremental. Tell us the application and we'll specify the right product, and the parts around it, for your machine.
Engineering support · Product sourcing · Procurement
Get help selecting and sourcing encoders and feedback
Send your part number or describe the application. We’ll review the requirement and help with product selection, sourcing, pricing and lead times.
- Exact parts and engineer-checked alternatives
- Manufacturer-direct options where available
- Standard, modified and custom solutions
No obligation to buy. Have a datasheet, drawing or nameplate photo? Reply to your confirmation email to attach it.
Need help choosing? Build a specification →Need help choosing? Open the specification builder
Spec builder
Specify encoders and feedback
Select every part you need, answer the questions an applications engineer would ask, and see your summary before we ask for any details.
- 1Products
- 2Performance
- 3Environment
- 4Volumes
- 5Your spec
An encoder tells the drive or controller where the axis is. In a servo system it closes the position and velocity loops; in a closed-loop stepper it catches lost steps; on a measuring axis it is the reference everything else is judged against. Getting the encoder wrong rarely shows up on the test bench. It shows up as a machine that has to home after every power cut, an axis that drifts when the enclosure warms up, or noise faults once the cable runs alongside the motor power.
This hub covers the decisions in the order we would take them: absolute or incremental, sensing technology, rotary or linear, interface, then accuracy and mounting. For a deeper comparison of the first decision, see absolute vs incremental encoders.
Absolute vs incremental encoders
An incremental encoder outputs a pulse train as it moves. The controller counts pulses from a known reference (an index pulse or home switch), so after power-up the axis must home before it knows where it is. Quadrature incremental encoders use two channels, A and B, 90 electrical degrees apart; which channel leads tells you direction. Counting every edge of both channels (“x4 decoding”) turns a 2,500 PPR encoder into 10,000 counts per revolution, according to Dynapar. A Z (index) channel gives one reference pulse per revolution.
An absolute encoder reports a unique position word at every point, so the axis knows where it is the moment power returns. Single-turn absolute encoders cover one revolution. Multi-turn versions also count revolutions through power loss using a gear train, a backup battery or self-powered counting such as Wiegand energy harvesting, as POSITAL explains. Batteries need replacing; gear trains add size and dislike shock; energy-harvesting designs avoid both but are not available in every format.
When to use which: choose absolute where homing is unsafe, slow or impossible (robot joints, vertical axes, machines that must restart mid-cycle, multi-axis gantries). Choose incremental where cost matters, a homing move is acceptable, or the drive only accepts A/B/Z.
Encoder technologies compared
| Technology | Strengths | Watch-outs | Typical use |
|---|---|---|---|
| Optical (disc or scale) | Highest resolution and accuracy; mature, wide choice | Sensitive to contamination, condensation and misalignment; tight mounting tolerances | Precision stages, semiconductor, metrology, high-end servo motors |
| Magnetic | Tolerant of dirt, oil and shock; compact; low cost | Lower accuracy than optical; can be disturbed by strong external magnetic fields | Motor feedback, AGVs, actuators, linear tape scales |
| Capacitive | Very thin and light; no magnets in the sensing path; large hollow bores | Check the maker’s environmental ratings; accuracy depends on mounting | Robot joints, gimbals, defence and aerospace pointing systems |
| Inductive | Very tolerant of misalignment, contamination and temperature; resolver-like robustness | Usually larger than optical for the same accuracy | Harsh-environment rotary axes, replacement for resolvers |
Control Engineering makes the point that no single technology wins everywhere: optical leads on performance but suffers in temperature extremes, contamination and shock, while inductive designs use the whole face of the rotor and stator rather than a single read point, so they tolerate misalignment far better.
Example series in each technology: Renishaw RESOLUTE and TONIC (optical), RLS AksIM-4 and the Bogen AKS16 heads (magnetic), Netzer VLX and multi-turn VLM (capacitive), and the Zettlex Mini Ultra IncOder (inductive).
Rotary vs linear, shafted vs bearingless
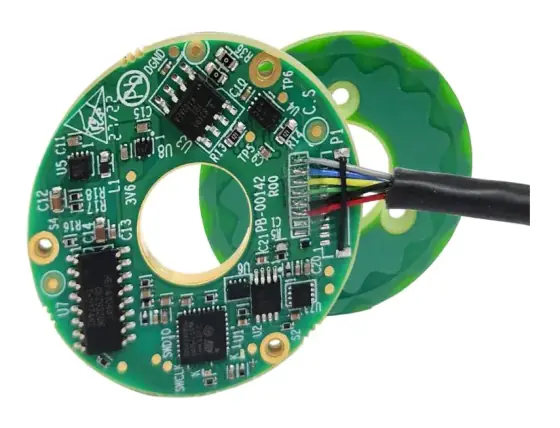
Rotary encoders come shafted (own bearings, coupled to your shaft), hollow-shaft, or bearingless ring/kit encoders where the rotor fits your shaft and the readhead fits your housing. Shafted units are simple to fit, but a flexible coupling adds lost motion, so they are not the first choice for high-accuracy angle measurement. Bearingless designs suit low axial height and large bores for cables or slip rings.
Linear encoders read a scale along the axis: open optical scales for clean, high-precision stages; enclosed scales such as Renishaw FORTiS-S for machine tools; magnetic tape such as Bogen LMSA for long, dirty axes; and capacitive options such as KappaSense FleXe where mounting tolerance is loose. Measuring at the load with a linear encoder removes screw lead error, backlash and thermal growth from the loop, which a motor-mounted rotary encoder cannot do.
Encoder interfaces: BiSS-C, SSI, EnDat, HIPERFACE DSL and quadrature
The interface must match what the drive reads. This is the most common reason a good encoder ends up on the wrong machine.
| Interface | Type | Key characteristics |
|---|---|---|
| Quadrature A/B/Z | Incremental, usually RS-422 differential | Universal; no position at power-up; count rate limits top speed |
| SSI | Absolute, one-way serial | Typically clocked 100 kHz to 2 MHz; optional parity only |
| BiSS-C | Absolute, bidirectional, open protocol | CRC checking, clock to about 10 MHz, parameter read/write |
| EnDat 2.2 | Absolute, bidirectional (HEIDENHAIN) | Up to 16 MHz clock over cables up to 100 m with propagation-delay compensation; diagnostics and safety-rated versions |
| HIPERFACE DSL | Absolute, fully digital (SICK) | Two wires inside the motor power cable; up to 100 m; 9.375 Mbaud |
Figures from Motion and Mechatronics, HEIDENHAIN and Motion Control Tips. Drive makers also use proprietary serial protocols (Siemens DRIVE-CLiQ, FANUC, Mitsubishi, Panasonic, Yaskawa and others); some encoder ranges, RESOLUTE among them, are offered in these variants so they can plug straight into that drive.
If your controller needs safety functions based on position (safe speed, safe limited position), you need a safety-rated encoder and interface, for example EnDat with its functional safety option, BiSS Safety or a safety-rated HIPERFACE DSL device.
How to select an encoder: resolution vs accuracy
Resolution is the smallest step reported; accuracy is the worst-case error against the true position. The RLS encoder handbook notes that higher resolution does not automatically mean higher accuracy, and gives a rule of thumb that repeatability is typically 5 to 10 times better than accuracy. That matters: many machines need repeatability more than absolute accuracy, and can be calibrated.
Useful conversions for rotary axes (there are 1,296,000 arc-seconds in a revolution):
- 17-bit (131,072 counts) is about 9.9 arc-sec per count
- 20-bit (1,048,576 counts) is about 1.24 arc-sec per count
- 23-bit (8,388,608 counts) is about 0.15 arc-sec per count
Worked example. A rotary table must place a part within ±5 µm at a 300 mm radius. The allowable angular error is 5 µm ÷ 300 mm = 16.7 µrad, about 3.4 arc-sec. The installed encoder accuracy therefore needs to be comfortably better than ±3.4 arc-sec, leaving budget for bearing runout and thermal effects. Resolution should be several times finer than that (a rule of thumb, so the servo loop can hold position without hunting), which points to 21 bits or more. A large-diameter ring encoder will usually be needed, because larger rings achieve better angular accuracy: Renishaw quotes RESOLUTE RESA30 ring system accuracy from about ±4.3 arc-sec on the smallest rings to about ±0.4 arc-sec on the largest.
Mounting tolerance and installation
Datasheet accuracy assumes the encoder is installed to its tolerances. Control Engineering notes that eccentricities below 0.025 mm are common requirements for optical ring encoders. By contrast, the Zettlex IncOder MINI guide allows 0.20 mm rotor-to-stator non-concentricity and a 0.30 to 0.70 mm axial gap on the 37 mm size. Design the housing, bearing and shaft so the encoder sees its required gap and concentricity across the full temperature range and under load, not just when the machine is cold and stationary.
Common encoder specification mistakes
- Choosing on resolution alone. A high bit count says nothing about installed accuracy.
- Interface mismatch. Check the drive’s exact supported protocol, clock rate and supply voltage before ordering.
- Single-turn on a multi-turn axis. If travel exceeds one motor revolution, plan for multi-turn or homing.
- Ignoring the environment. Coolant mist, condensation and swarf defeat open optical encoders; strong motor or brake fields can upset magnetic ones.
- Cable routing. Run encoder cables screened and away from motor power, or choose a one-cable system designed for it.
- Measuring at the wrong place. If accuracy matters at the tool, put a linear or load-side encoder there.
What to send us for an encoder quote
- Rotary or linear; shaft, bore or scale length; space envelope
- Accuracy and repeatability required at the load, and the radius or stroke
- Maximum speed (rpm or m/s)
- Absolute or incremental; single- or multi-turn; number of turns
- Drive or controller make and model, and required interface
- Environment: temperature range, IP rating, contamination, shock and vibration, magnetic fields
- Any functional safety requirement (SIL or PL)
- Annual volumes and target cost
You can capture these in the spec builder and our engineers will propose suitable options from our supply network. Related families: servo drives, servo and stepper motors and frameless torque motors.
Guides
Where encoders and feedback are used
What we need to know to specify encoders and feedback
These are the questions an applications engineer works through first. Approximate answers are fine: ranges narrow the options quickly, and we confirm the details with you.
- Motion: Rotary, Linear
- Output: Absolute, Incremental
- Resolution: Standard, High, Ultra-high
- Interface: BiSS-C, SSI, EnDat, A/B/Z, Not sure
- Mounting: Hollow shaft / ring, Shaft, Open scale and readhead
We also ask about the environment (washdown, outdoor, subsea, ATEX, vacuum, shock and EMC), annual quantities and timescale, because these decide whether a standard, modified or custom design is the best fit.
106 series compared
Series from 17 manufacturers, grouped by type. Figures are the highest published for each series. Open a series for the full specification and, for brands outside our supply network, the alternatives that meet or exceed it.
Magnetic rotary encoder (32)
| Brand | Series | Resolution | Speed |
|---|---|---|---|
| Bogen | AKS16 / AKS16-MT | 20 bit | — |
| Bogen | AKS17 | 24 bit | — |
| Bogen | AKP18 | 20 bit | — |
| Bogen | IKS9 / IKS9.1 | — | — |
| Bogen | IKS11 / IKP11 | — | — |
| Bogen | IKS15 / IKS15.1 | — | — |
| Bogen | IKS23 | — | 16 m/s |
| Bogen | RMSI | — | — |
| Bogen | RMSN | — | — |
| HEIDENHAIN | ERM 2000 modular magnetic | — | — |
| Renishaw | RLS RMB30 | 13 bit | — |
| Renishaw | RLS RM08 | 12 bit | — |
| Renishaw | RLS RE16 | — | — |
| Renishaw | RLS AksIM-4 | 21 bit | — |
| Baumer | MAGRES EAM580 | 25 bit | — |
| Baumer | MAGRES EAM580R | 12 bit | — |
| SICK | AHS/AHM36 | 26 bit | — |
| RLS | AksIM-2 | 20 bit | — |
| RLS | AksIM-4 HIPERFACE DSL | 20 bit | — |
| RLS | Orbis | 14 bit | — |
| RLS | RM44 / RM58 | 14 bit | — |
| POSITAL | IXARC Fieldbus Classic absolute encoders | 31 bit | — |
| POSITAL | IXARC MCS PROFIsafe safety encoder | 25 bit | — |
| POSITAL | IXARC IO-Link absolute encoders | — | — |
| POSITAL | IXARC kit encoders | 33 bit | — |
| POSITAL | IXARC programmable incremental encoders | — | — |
| POSITAL | IXARC ATEX encoders | — | — |
| Pepperl+Fuchs | ENA58IL | — | — |
| Pepperl+Fuchs | ENA36IL | 32 bit | — |
| Pepperl+Fuchs | ENA42HD | 31 bit | — |
| Baumer | HMG10 / PMG10 HeavyDuty absolute | 29 bit | — |
| Lika Electronic | MS36 / MSC36 | 13 bit | — |
Optical absolute encoder (24)
| Brand | Series | Resolution | Speed |
|---|---|---|---|
| HEIDENHAIN | ECN / EQN 400 | 25 bit | — |
| HEIDENHAIN | ECN / EQN 1000 | 23 bit | — |
| HEIDENHAIN | ECN / EQN 1300 (motor feedback) | 25 bit | — |
| HEIDENHAIN | RCN 2001 / RCN 5001 angle encoders | 28 bit | — |
| HEIDENHAIN | RCN 6000 angle encoder | 28 bit | — |
| HEIDENHAIN | RCN 8001 angle encoder | 29 bit | — |
| HEIDENHAIN | LIC 2100 / 3100 / 4100 exposed absolute linear | — | 10 m/s |
| Renishaw | RESOLUTE | 32 bit | 100 m/s |
| Renishaw | EVOLUTE | — | 100 m/s |
| Hengstler | ACURO AC58 | 34 bit | — |
| Hengstler | ACURO AD36 | 34 bit | — |
| Hengstler | ACURO AD37 | 32 bit | — |
| Hengstler | ACURO AX73 | 22 bit | — |
| Kübler | Sendix 5868 / 5888 | 28 bit | — |
| Kübler | Sendix F5868 / F5888 | 32 bit | — |
| SICK | AFS/AFM60 | 30 bit | — |
| SICK | EKS/EKM36 | 32 bit | — |
| POSITAL | IXARC Ethernet absolute encoders | 30 bit | — |
| Pepperl+Fuchs | AVM78E / CVM78E flameproof | 30 bit | — |
| Baumer | OptoTurn EAL580 | 31 bit | — |
| Lika Electronic | EHO58 / EHM58 | 40 bit | — |
| Lika Electronic | EHCT59 | 40 bit | — |
| TR-Electronic | C__582 absolute encoders | 18 bit | — |
| TR-Electronic | CD_75 safety absolute encoders (SIL3/PLe) | — | — |
Optical incremental encoder (18)
| Brand | Series | Resolution | Speed |
|---|---|---|---|
| HEIDENHAIN | ERN incremental rotary encoders (ERN 100 / 400 / 1000 / 1300) | — | — |
| HEIDENHAIN | LIP 200 / LIP 6000 exposed linear | — | 3 m/s |
| HEIDENHAIN | LIF 400 exposed linear | — | — |
| maxon | ENX | 17 bit | — |
| Renishaw | TONiC | — | 10 m/s |
| Renishaw | VIONiC | — | 12 m/s |
| Renishaw | QUANTiC | — | 24 m/s |
| Renishaw | ATOM | — | 20 m/s |
| Renishaw | ATOM DX | — | 20 m/s |
| Hengstler | ICURO RI58 | — | — |
| Kübler | Sendix 5000 / 5020 | — | — |
| SICK | DFS60 | — | — |
| Pepperl+Fuchs | ENI58IL | — | — |
| Pepperl+Fuchs | ENI58PL | — | — |
| Baumer | optoPulse EN580E.IL | — | — |
| Baumer | HOG10 / POG10 HeavyDuty | — | — |
| Lika Electronic | I58 / I58S | — | — |
| TR-Electronic | IE58 / IH58 incremental encoders | — | — |
Magnetic linear encoder (12)
| Brand | Series | Resolution | Speed |
|---|---|---|---|
| Bogen | ALS21 | — | 10 m/s |
| Bogen | xMARS | — | — |
| Bogen | LMSI | — | — |
| Bogen | LMSA | — | — |
| Bogen | LMSN | — | — |
| Bogen | LMSB | — | — |
| Renishaw | RLS HiLin | — | 25.28 m/s |
| Renishaw | RLS LinACE InAxis | — | — |
| RLS | LM10 | — | — |
| RLS | LA11legacy | — | 7 m/s |
| Lika Electronic | SME21 | — | — |
| TR-Electronic | LMC55 magnetostrictive linear encoder | — | — |
Capacitive rotary encoder (9)
| Brand | Series | Resolution | Speed |
|---|---|---|---|
| Netzer Precision | VLP | 23 bit | — |
| Netzer Precision | VLX | 23 bit | — |
| Netzer Precision | VLA | — | — |
| Netzer Precision | VLT | 23 bit | — |
| Netzer Precision | VLZ | 26 bit | — |
| Netzer Precision | VLS | 23 bit | — |
| Netzer Precision | VLM | 32 bit | — |
| Netzer Precision | DS | 23 bit | — |
| Netzer Precision | DL | 22 bit | — |
Enclosed linear encoder (5)
| Brand | Series | Resolution | Speed |
|---|---|---|---|
| HEIDENHAIN | LC 100 / LC 200 / LC 400 sealed absolute linear | — | — |
| HEIDENHAIN | LS 100 / LS 400 sealed incremental linear | — | — |
| HEIDENHAIN | LF 185 sealed incremental linear | — | — |
| Renishaw | FORTiS-S | — | 4 m/s |
| Renishaw | FORTiS-N | — | 4 m/s |
Inductive encoder (4)
| Brand | Series | Resolution | Speed |
|---|---|---|---|
| Novanta | Mini Ultra IncOder | 20 bit | — |
| Novanta | Midi Ultra IncOder | 22 bit | — |
| LTN Servotechnik | LTN frameless resolvers | — | — |
| LTN Servotechnik | LTN housed resolvers | — | — |
Capacitive linear encoder (2)
Summarised from manufacturers' published data. Always confirm against the current datasheet; an engineer will check the fit before recommending anything.
Brands
Engineer support
Talk to an engineer about encoders and feedback
Tell us what you need, whether it is this part, an equivalent or a complete axis built around it. An engineer will review your requirements and reply, normally within one working day.
- Reviewed by an engineer, not an autoresponder
- Like-for-like and better-fit alternatives
- Standard, modified and custom options
Prefer to configure it? Use the spec builder.
From component to working requirement
Applications and engineering services
Explore selection questions, replacement routes and complete motion packages. Keep the application requirements alongside the product specifications.
Motors, encoders and slip rings for gimbals
Smooth low-speed motion, payload balance, disturbance rejection and cable routing can matter more than a headline peak torque figure.
Hollow-shaft absolute encoder selection
A usable bore, a high bit count and an absolute position output do not by themselves establish a suitable encoder. Check the installed mechanical and electrical arrangement.
Precision motion for laboratory positioning
A laboratory positioning requirement should specify the result at the sample or tool. Resolution, repeatability and absolute accuracy are different requirements.
Servo motor and drive compatibility review
A compatible system needs more than matching power and voltage. Establish the feedback, motor constants, current conventions, controller interface and commissioning route.