
Typical requirements
| CT gantry rotation time (published example) | Down to 0.25 s per turn, i.e. 240 rpm (Siemens SOMATOM Force) |
|---|---|
| CT gantry aperture and table load (same example) | 78 cm bore; table load up to 307 kg; scan speed up to 737 mm/s |
| Large CT slip ring capability (published) | Bore up to 2,000 mm, 300+ rpm, up to 1,000 V DC and 300 A |
| Contactless capacitive data link (published) | Up to 340 Gbit/s (SCHLEIFRING GigaCAP) |
| Gantry servo loop closure (published) | As little as 62 µs (Kollmorgen) |
| Mobile C-arm motion (published example) | Orbital +95° to −65°, angulation ±210°, 450 mm vertical, ±12° wig-wag |
| MR labelling terms (ASTM F2503) | MR Safe, MR Conditional, MR Unsafe |
Machinery we specify motion for
- CT scanner gantries
- Intra-operative and mobile CT
- CT and radiology patient tables
- X-ray C-arms and mobile fluoroscopy
- X-ray tube and detector positioning
- MRI patient handling and in-bore devices
- Radiography stands and ceiling suspensions
- Industrial and security CT
What imaging systems demand from motion
This page builds on our medical and laboratory overview, which covers IEC 60601-1 component evidence and the basics of CT slip ring specification. Here we go through the whole imaging system: gantry, slip ring, patient table, C-arm and the special case of MRI.
Imaging motion has one overriding requirement: the system must know exactly where everything is when each image sample is taken. Kollmorgen’s imaging case study puts it as microns and microseconds making the difference between a clear image and artefacts. In a 320-slice cardiac CT, images are captured only while the heart is at rest between beats, so gantry motion, X-ray timing and ECG data must line up. Kollmorgen says its servo loops close in as little as 62 µs for this kind of work.
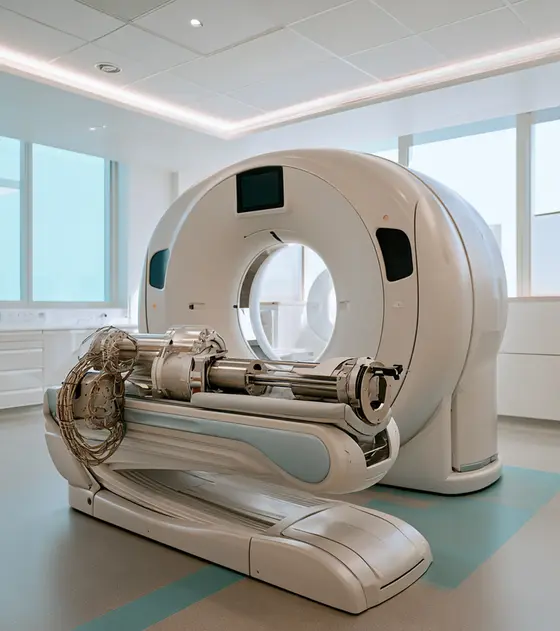
The loads are large. A modern CT gantry carries the X-ray tube, generator parts and detector around a 78 cm bore, and tables carry patients of up to 307 kg on published scanners such as the Siemens SOMATOM Force, which also quotes a rotation time down to 0.25 s and a scan speed of up to 737 mm/s.
Where motion sits in an imaging system
| Subsystem | Motion | Components | What decides the choice |
|---|---|---|---|
| CT gantry | Continuous rotation at scan speed | Direct drive ring motor or belt drive, bearing, slip ring, angle encoder | Inertia, velocity ripple, data rate |
| CT tilt (some models) | Limited tilt of the gantry | Gearmotor or actuator with brake | Holding torque, safe stop |
| Patient table | Vertical lift, horizontal travel | Electric cylinder, ballscrew module, absolute linear scale | Load, smoothness, power-loss behaviour |
| C-arm | Orbital, angular, vertical, wig-wag | Servo motors, low-backlash gears, brakes, absolute encoders | Offset load, stiffness, collision safety |
| Tube and detector stands | Vertical travel, tilt | Linear actuators, gearmotors, counterbalance | Positioning repeatability |
| MRI | Table travel, in-bore devices | Remote motors, non-magnetic actuators | MR labelling, image quality |
| Industrial CT | Part rotation and manipulation | Direct drive rotary stage, linear axes, slip ring | Accuracy, stiffness |
CT gantries: direct drive and the forces involved
A gantry at 0.25 s per turn is spinning at 240 rpm, or about 25 rad/s. Two consequences follow for motion design.
Worked example: gantry drive and centripetal load
Assume a rotating assembly of 800 kg with a radius of gyration of 0.5 m, bearing and brush friction of 50 Nm, and a spin-up to 240 rpm in 20 s. These are illustrative figures, not a scanner’s data.
- Inertia. J = 800 × 0.5² = 200 kg·m².
- Acceleration torque. α = 25.1 / 20 ≈ 1.26 rad/s², so T = 200 × 1.26 ≈ 251 Nm. Add 50 Nm friction: about 300 Nm during spin-up.
- Power. At the end of spin-up, 300 Nm × 25.1 rad/s ≈ 7.5 kW. At steady speed only friction remains: 50 × 25.1 ≈ 1.3 kW.
- Braking. Stopping in the same 20 s puts about ½ × 200 × 25.1² ≈ 63 kJ back into the drive, so plan a braking resistor or regenerative supply.
- Centripetal load. A component at 0.6 m radius sees ω²r ≈ 25.1² × 0.6 ≈ 380 m/s², about 39 g. Brush blocks, connectors and any encoder read head on the rotor must be rated for that.
A direct drive suits this duty because the control loop sees the ring itself with no belt in between, as Kollmorgen describes for imaging gantries. Arc-segment ironless motors such as the Akribis ACR are built for large radii, with no cogging and no attraction force. Check the stray field near detectors, and ask for velocity ripple at scan speed.
CT slip rings beyond the basics
The overview page covers bore, surface speed, power and data. Two developments are worth knowing. First, contactless data rates keep rising: SCHLEIFRING quotes up to 340 Gbit/s for its GigaCAP capacitive technology, alongside power up to 1,000 V DC and 300 A on brushes, bores up to 2,000 mm and speeds of 300 rpm and above. Second, CT is moving into theatres. SCHLEIFRING describes an intra-operative CT that must send real-time image data from two sources in a very tight installation space, which pushes ring designers towards thinner, lighter rotors.
Medical CT rings are engineered to the scanner. For industrial or security CT, retrofits and prototypes, catalogue units such as the Large Size Slip Ring (bores quoted up to 1,000 mm) or a fibre optic integrated slip ring are a starting point. See our slip rings for medical imaging page and the large-diameter type.
Patient tables and C-arms
Tables have two very different axes. The lift carries the full patient load slowly and must hold it on power loss. The horizontal axis moves the patient through the beam smoothly at scan speed. Specify them separately, with an absolute linear scale such as the Bogen LMSA where the table must know its position at power-up.
C-arms move heavy, offset loads around the patient. A published mobile unit from MXR Imaging offers +95° to −65° orbital rotation, ±210° angulation, 450 mm vertical travel and ±12° wig-wag. Harmonic Drive lists precise, safe positioning of X-ray generators, detectors and C-arms among its medical uses. Size each axis on the unbalanced moment at its worst angle, use low-backlash gearing and holding brakes, and define what each axis does on a collision or emergency stop. IEC 60601-2-54 covers radiography and radioscopy equipment such as these.
Industrial and security CT
The same gantry and slip ring technology appears outside medicine: SCHLEIFRING lists security inspection and industrial CT alongside medical scanners. Industrial CT often rotates the part on a precision stage instead of spinning the source, so a housed direct drive with an integrated encoder, plus stiff linear axes for magnification, does the job. The duty is slower, but accuracy and stiffness are tighter.
MRI: when motors cannot go near the magnet
ASTM F2503 defines three labels. MR Safe means no known hazards in any MR environment; MR Conditional means demonstrated safety within defined conditions; MR Unsafe means unacceptable risks. Conventional permanent-magnet motors, steel gearboxes and many encoders are unsuitable near the bore.
Two approaches work. Keep motors well away from the magnet and transfer motion mechanically, or use non-magnetic actuators. In an MRI-guided prostate robot, Eslami et al. built all components from non-ferrous, non-magnetic materials and drove each axis with a non-magnetic ultrasonic motor of up to 1 Nm. Signal-to-noise varied by no more than 15.35% across the first six test states at 3 T, and the authors describe the robot as classifiable as MR Conditional. Ask any supplier for a non-magnetic build and test evidence, never assume it.
Typical pitfalls
- Sizing the gantry for steady speed only. Spin-up, braking energy and centripetal load on rotor parts set the design.
- Ignoring velocity ripple. It becomes timing error in the image.
- Treating the table as one axis. Lift and travel have different loads, speeds and safety needs.
- Calling a motor “MRI compatible” without an F2503 label and test conditions.
- Forgetting EMC. Generators and detectors are both noisy and sensitive; screen and filter drive cables.
What to send us
Send the axis list with loads, ranges, speeds and duty, the slip ring circuit and data list, and the envelope. Add the system’s particular standard, EMC constraints and any MR environment. Our specialist engineering and supply partners will come back with a proposal for your design review.
Slip rings for CT scanners
A CT slip ring wraps the patient aperture and carries high-voltage generator power, control signals and detector data across a gantry that turns several times a second. Power runs on brushes; image data usually crosses a contactless capacitive or optical link, because sliding contacts cannot carry tens to hundreds of gigabits per second reliably. Medical CT rings are normally engineered to the scanner. Large-bore, hybrid fibre and pancake designs are starting points for industrial and security CT, intra-operative systems and retrofits. Specify bore, envelope, speed, power per ring, data rate and direction, debris limits and service intervals.
- CT gantry: generator power to the X-ray tube
- CT gantry: detector data off the rotor
- Industrial and security CT: power and data on large rotating stages
- Intra-operative CT: compact ring in a tight envelope
Available through our supply network
All slip rings →Specify slip rings for medical imaging (ct, mri and x-ray) →
Direct drive motors for CT gantries
A direct drive gantry motor removes the belt and pulley between motor and ring, so there is no compliance, backlash or belt wear, and the control loop sees the gantry directly. Large-radius arc-segment motors mount around the ring itself; housed direct drives suit smaller rotating stages such as industrial CT turntables. Size from the rotating inertia, the spin-up time to scan speed, bearing and brush friction, and the braking case. Ask for velocity ripple at scan speed, because speed variation shows up as image artefacts, and check the magnetic stray field near detectors.
- CT gantry: ring drive at scan speed
- Industrial CT: rotary stage for the part
- C-arm and gantry rotation: smooth direct-drive axes
- Radiotherapy-style rings: precise rotation of heavy assemblies
Available through our supply network
All frameless and torque motors →Specify frameless and torque motors for medical imaging (ct, mri and x-ray) →
Patient table actuators for CT and radiology
Imaging tables lift the patient to the gantry, then move them horizontally through the beam at a controlled speed during a scan. The vertical axis is a high-force, low-duty lift that must hold its load on power loss; the horizontal axis needs smooth, repeatable travel. Specify the patient load with margin, stroke, speed, positioning repeatability, duty cycle, noise and the behaviour on power failure. Ball-screw electric cylinders suit lifts; ballscrew linear modules suit horizontal travel; self-locking DC actuators suit simpler tables and positioning aids.
- CT tables: vertical lift and tilt
- CT tables: horizontal patient travel through the gantry
- Radiography tables: height and float axes
- Detector stands: vertical detector travel
Available through our supply network
All linear actuators →Specify linear actuators for medical imaging (ct, mri and x-ray) →
C-arm motors and drives for X-ray positioning
Motorised C-arms rotate the arc orbitally and angularly, lift the column and move the base, often on a mobile cart with batteries. Low-voltage servo motors suit battery-powered mobile units; AC servo motors suit fixed rooms and ceiling-mounted systems. Specify torque at the slowest and fastest required speeds, the unbalanced load of tube and detector at each angle, holding brakes, collision-detection needs and audible noise. Absolute encoders let the system know arm position at power-up without a homing move near the patient.
- Mobile C-arms: orbital and angular rotation
- Fixed C-arms: column, arc and table axes
- Ceiling suspensions: tube positioning
- Detector stands: vertical and tilt
Available through our supply network
All servo and stepper motors →Specify servo and stepper motors for medical imaging (ct, mri and x-ray) →
Gearboxes for C-arms and detector positioning
C-arm and detector axes move heavy, offset loads slowly and must stop exactly where the clinician wants, so low backlash and high stiffness matter more than speed. Hollow-shaft strain-wave units leave room for cables through the axis; hollow rotary platform reducers with crossed roller bearings carry heavy tilting loads; precision planetaries suit linear and column drives. Specify output torque including the unbalanced moment at the worst angle, ratio, backlash, torsional stiffness, bore and the emergency-stop torque the gear must survive.
- C-arms: orbital and angulation reducers
- Detector and tube positioning: tilt axes
- Patient tables: lift and travel reducers
- Ceiling suspensions: rotation axes
Available through our supply network
All gearboxes and harmonic drives →Specify gearboxes and harmonic drives for medical imaging (ct, mri and x-ray) →
Encoders for medical imaging gantries and tables
Image reconstruction needs to know where the gantry, table and C-arm are at every moment, so feedback accuracy and update timing both matter. Large-bore capacitive and inductive encoders fit around rotating axes; absolute magnetic linear scales measure table travel without homing. Specify bore, accuracy, resolution, interface and update rate, the speed range, and immunity to the electrical noise of high-voltage generators. For a gantry larger than any ring encoder, ask about tape scales on the ring or an encoder integrated into the slip ring.
- CT tables: absolute horizontal and vertical position
- C-arms: orbital and angulation angle
- Rotating stages: angle for reconstruction
- Detector stands: position feedback
Available through our supply network
All encoders and feedback →Specify encoders and feedback for medical imaging (ct, mri and x-ray) →
Servo drives for gantry and table axes
Gantry and table drives need fast, stable current and velocity loops, safe stopping, and EMC behaviour that will pass IEC 60601-1-2 in the finished system. Wide-voltage drives with STO cover high-inertia gantry and table axes; dedicated linear and direct-drive drives suit ring motors. Specify supply voltage, continuous and peak current, feedback type, fieldbus, STO and other safety functions, and the filtering and cable screening needed near detectors and generators. Ask for regenerative braking data, because a heavy gantry returns a lot of energy when it stops.
- CT gantries: direct-drive ring control
- Patient tables: lift and travel axes
- C-arms: multi-axis coordinated motion
Available through our supply network
All servo drives →Specify servo drives for medical imaging (ct, mri and x-ray) →
Standards to have in view
- IEC 60601-1 (medical electrical equipment, basic safety and essential performance)
- IEC 60601-1-2 (EMC for medical electrical equipment)
- IEC 60601-2-44 (X-ray equipment for computed tomography)
- IEC 60601-2-54 (X-ray equipment for radiography and radioscopy)
- IEC 60601-2-33 (magnetic resonance equipment for medical diagnosis)
- ASTM F2503 (marking items for safety in the MR environment)
- ISO 14971 (medical device risk management)
Which standards apply depends on the end product and its market. Your engineer will confirm what the component itself needs to meet.